



LRPT-06D100K-A Payload Upper To 100Kg high load hexapod
LRT high load hexapod is fast response, high precision, and it's supported by a strong and experienced technical team. We provide customers with complete one-stop solutions! Adequate supply, fast shipping, timely delivery, to provide quality products and services, Our products are through strict testing, reliable quality, welcome to consult.
The turntable control system adopts a fully digital servo control system. The attitude measurement device measures the real-time posture of the upper platform. Through motion calculation, the command posture of the upper platform is determined. The monitoring computer sends the command posture to the microcontroller via Ethernet. Upon receiving the motion parameter commands, the microcontroller performs a spatial motion model transformation. Using inverse kinematics computation, it calculates the drive motor rotation angle, which is transmitted to the driver via the bus. The driver's internal PC processes the information and drives the electric motor, allowing the platform to reach the designated posture. The encoder mounted on the electric motor detects torque, speed, and position information in real-time, sending it to the driver. A closed-loop control system ensures precise real-time control of the motor's rotation angle. The information is also transmitted to the microcontroller, which uses inverse computation to determine the current posture of the upper platform as a reference for calculations.
Product details
Large carrying capacity Safe and Reliable Sturdy and Durable
|
DOF |
Range |
Velocity |
Acceleration |
|
Pitch |
±13° |
±30°/s |
±150°/s2 |
|
Roll |
±13° |
±30°/s |
±150°/s2 |
|
Yaw |
±15° |
±30°/s |
±150°/s2 |
|
Sway |
±0.10m |
0.5m/s |
5m/s2 |
|
Surge |
±0.10m |
0.5m/s |
5m/s2 |
|
Heave |
±0.08m |
0.5m/s |
5m/s2 |
|
|
|
Unit: mm |
|
Weight: 145kg |
|
Color: Black |
|
Material: Aluminum alloy + Steel |
|
Payload: 100kg |
|
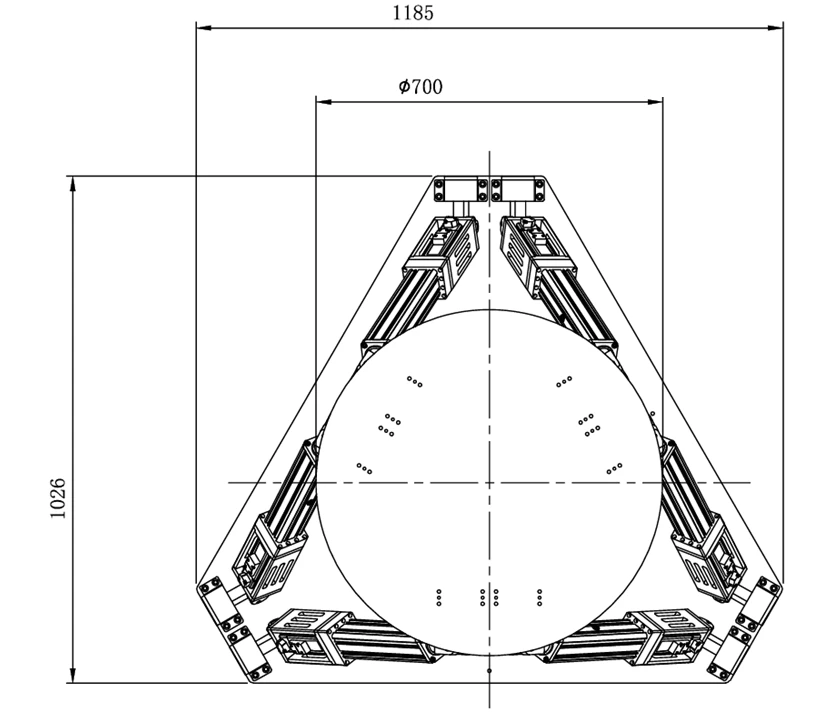
Size: 1026mm*1185mm*750mm |
|
Size of Payload: ≤1000mm*1000mm*400mm |
|
Installation method: Threaded hole |
|
Mounting Hole Distance: Customize |
Electrical parameters
|
Power requirements |
Rated Voltage: 220V AC(Range:-10%~10%) |
|
Rated frequency: 50hz(Range:-5%~5%) |
|
|
Rated power: 1.8Kw |
|
|
Peak power: 2.4Kw |
|
|
Environment Requirements |
Storage environment: Temperature:-30~65℃ Humidity:5%~95% Atmospheric pressure:85~108Kpa Protection Level:IP54 |
|
Work environment: Temperature:-20~50℃ Humidity:5%~95% Atmospheric pressure:85~108Kpa Protection Level:IP54 |
Safety design
Mechanical Structural Safety Design:
All key load-bearing components are designed in accordance with national military standards, with a mechanical design safety factor of no less than 3.0 and a drive margin of no less than 3.0.
Electrical Design Safety Features:
To ensure the safe and reliable operation of the system and prevent damage to the platform structure in case of system failure, a three-level protection function is implemented: software protection, circuit protection, and hardware protection.
Software Protection:
As the first level of protection, software protection is the most basic safeguard and operates during the system control software runtime. In the experimental motion platform system control software design, thresholds are set for the maximum travel distance, operating speed, and acceleration of the motor to prevent overshooting caused by over-travel or over speed during motor operation.
Circuit Protection:
As the second level of protection, circuit protection operates during the system's power-on runtime. The system motor drive controller sets thresholds for the motor output code value, maximum speed, acceleration, and maximum output current to prevent overshooting caused by motor over speed. Additionally, limit switches are installed at critical extreme positions. The circuit logic of these limit switches is linked to the drive. When the system's moving components reach an extreme position, reverse output of the drive is disabled to prevent over-travel during screw motion.
Hardware Protection:
As the third and highest level of protection, hardware protection operates throughout the entire lifecycle of the system after installation and acceptance. It ensures that under any scenario, the experimental platform structure remains intact, user test equipment is undamaged, and the platform structure remains secure under all operating and storage conditions.
Additional Safety Modules:
The system is equipped with comprehensive safety protection functions, as listed below:
Console Emergency Stop Button:
During operation, if abnormal conditions are detected, the operator in the control room can press the emergency stop button to immediately halt the equipment and maintain the current position.
Console Stop Button:
During operation, if abnormal conditions are detected, the operator can press the stop button to immediately halt the equipment and maintain the current position.
Automatic Power Failure and Short-Circuit Protection for the Experimental Platform:
In case of a 220V power failure or short circuit, the indicator light turns off, the motor brake engages, and the equipment maintains its current position.
Automatic Motor Overload Protection:
The system's servo motor can handle 3 times overload. If the drive detects motor overload, it triggers an alarm signal, engages the motor brake, and the equipment maintains its current position.
Automatic Motor Over-Temperature Protection:
If the drive detects excessively high motor temperature, it triggers an alarm signal, engages the motor brake, and the equipment maintains its current position.
Automatic Motor Encoder Fault Protection:
In case of motor over speed, stall, or excessive impact, the drive detects an encoder fault, triggers an alarm signal, engages the motor brake, and the equipment maintains its current position.
Automatic Drive Current Overload Protection:
If the drive current overloads, it triggers an alarm signal, engages the motor brake, and the equipment maintains its current position.
Automatic Drive Overvoltage Protection:
If the drive experiences overvoltage, it triggers an alarm signal, engages the motor brake, and the equipment maintains its current position.
Automatic Drive Over-Temperature Protection:
If the drive temperature is excessively high, it triggers an alarm signal, engages the motor brake, and the equipment maintains its current position.
Automatic Limit Switch Detection Protection:
When the moving components of the experimental platform reach an extreme position, the drive and control computer simultaneously block forward input motion signals, allowing only movement away from the extreme position.
Automatic Motor Speed Limit Protection:
During operation, if the control system detects speed exceeding the limit, the motor brake engages, and the equipment maintains its current position.
Automatic Motor Acceleration Limit Protection:
During operation, if the control system detects acceleration exceeding the limit, the motor brake engages, and the equipment maintains its current position.
Automatic CAN Bus Communication Fault Protection:
During operation, if the control system detects a CAN bus communication fault, the motor brake engages, and the equipment maintains its current position.
Automatic Network Communication Fault Protection:
During operation, if the control system detects a network communication fault, the motor brake engages, and the equipment maintains its current position.
Automatic Main Control Computer Fault Protection:
During operation, if the monitoring computer detects no response from the main control computer, the motor brake engages, and the equipment maintains its current position.


FAQ
A Hexapod is a specialized system capable of simulating all possible motions of an object in three-dimensional space. Its name directly reflects its function: providing six independent degrees of freedom of movement.
These six degrees include three translational degrees of freedom and three rotational degrees of freedom:
- Three Translational Degrees of Freedom:
1.Heave: Vertical movement along the Z-axis (up and down).
2.Sway: Lateral movement along the Y-axis (left and right).
3.Surge: Longitudinal movement along the X-axis (forward and backward).
- Three Rotational Degrees of Freedom:
4. Yaw: Rotation around the Z-axis (left and right turning).
5. Pitch: Rotation around the Y-axis (nodding forward and backward).
6. Roll: Rotation around the X-axis (tilting side to side).
Core Working Principle & Structure
The most common type of 6-DOF platform uses the Stewart Platform configuration, a type of parallel robot mechanism. Its core components include:
Top Platform
Also known as the moving platform, it carries the payload (e.g., a cockpit, simulator, test equipment).
Base Platform
Also known as the fixed platform, it is mounted to the foundation.
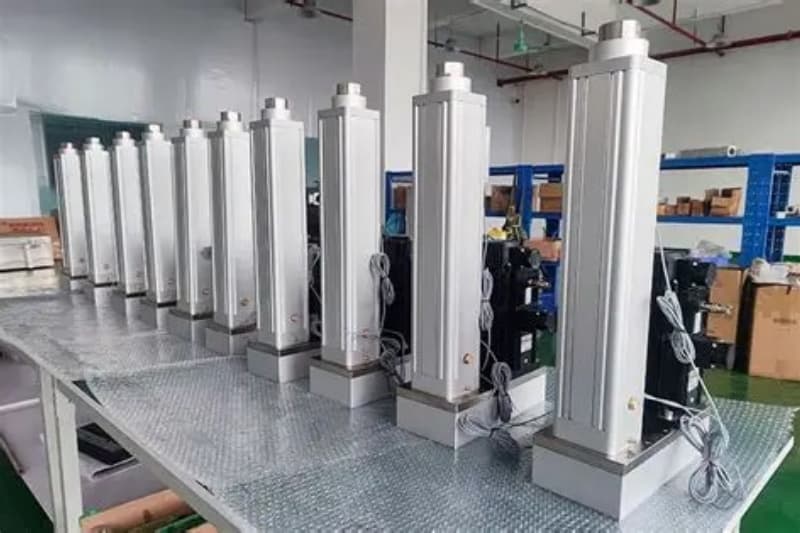
Six Extendable Electric Cylinders
These are the core actuators of the platform. Each is connected at both ends to the top and base platforms via universal joints or spherical hinges.
Working Principle:
The control system calculates the precise length each of the six electric cylinders needs to extend or retract based on the desired motion path. The coordinated lengthening and shortening of these six cylinders push and pull the top platform in unison, synthesizing the required complex motion across all six degrees of freedom. For example, to simulate an aircraft pitching up, the control system would command the front cylinders to extend and the rear cylinders to retract.
Key Features & Advantages
High Stiffness & Load Capacity
The parallel structure distributes the load across the six struts, making it very robust and capable of withstanding significant forces.
High Precision & Dynamic Response
Electric cylinder actuation enables highly precise motion with fast response times, capable of simulating high-frequency vibrations and rapidly changing orientations.
High Flexibility
Capable of achieving complex multi-axis motions within a compact space.
Proven Technology
The theory and practice behind the Stewart platform are well-established, ensuring high reliability.
Typical Applications
Due to their exceptional motion capabilities, 6-DOF platforms are indispensable in numerous high-end fields:
- Flight Simulators: The classic application, providing pilots with realistic kinesthetic feedback for takeoff, landing, turbulence, and aerobatics.
- Driving Simulators: Used for simulating the operation of cars, tanks, and ships, for vehicle performance testing, driver training, and virtual prototyping.
- Motion Theaters / Entertainment Rides: Provide immersive entertainment experiences, moving the audience in sync with the film's action.
Research & Testing:
- Vibration Simulation: Simulating the effects of earthquakes, road roughness, etc., on structures or equipment.
- Attitude Simulation: Used for ground-based attitude simulation testing of satellites, spacecraft, antennas, etc.
- Precision Machining & Docking: Used in advanced manufacturing and assembly processes requiring high-precision pose adjustment.
Connection to Related Technologies
As you learned previously, electric cylinders are the core actuators constituting a high-performance 6-DOF platform. The platform's performance (e.g., accuracy, speed, force) directly depends on the performance of the electric cylinders used. Furthermore, the critical safety protection functions (such as limit switches, overload protection, emergency stop) for such a complex system align perfectly with the safety design and electrical protection concepts you inquired about earlier.
Hot Tags: LRPT-06D100K-A Payload Upper To 100Kg high load hexapod, China LRPT-06D100K-A Payload Upper To 100Kg high load hexapod manufacturers, 100kg high load hexapod, hydraulic hexapod, 3 servo hexapod, high load hexapod, hexapod, large hexapod
Next
No InformationYou Might Also Like


Send Inquiry